Contributions of Single-cell Mechanics and Cell-cell Adhesion to Multicellular Spheroid Mechanics
Persistent Identifier
Use this permanent link to cite or share this Morpheus model:
Micropipette aspiration (MPA) of single cells and multicellular spheroids
Introduction
Tumor spheroid mechanics arise from both the mechanical properties of individual cells and the adhesive interactions that organize them into tissues. The relative contribution of these two factors to the bulk mechanical behavior, however, remains difficult to disentangle experimentally. Here, we develop a computational model of micropipette aspiration to compare the mechanical response of isolated cells and multicellular spheroids within a common computational framework. By independently varying single-cell stiffness and cell-cell adhesion, we quantify their effects on aspiration dynamics, effective elastic modulus, and viscoelastic relaxation.
Description
All simulations were performed on a two-dimensional square lattice. Cellular resistance to deformation is varied through the strength of the SurfaceConstraint plugin, used in aspherity mode. The perimeter constraint strength, $\lambda_\mathrm{S}$, controls the effective resistance to changes in cell shape. Cell-cell adhesion is controlled by the contact energy parameter $J$, where lower (more negative) values correspond to stronger adhesion. Aspiration was applied by DirectedMotion which biases movement and can be applied locally on the grid (even on parts of the cell).
In single-cell-aspiration.xml, we simulated micropipette aspiration by applying an effective aspiration force within the pipette region (Figure 1, Video 1). The pipette walls were represented by two stationary (frozen) cells positioned in parallel.
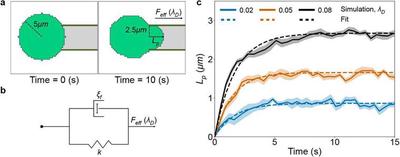
single-cell-aspiration.xml) of single-cell micropipette aspiration (MPA). (a) Two-dimensional CPM simulation of single-cell MPA under a constant effective aspiration force parameter $\lambda_\mathrm{D}$. (b) Kelvin-Voigt model of viscoelasticity used to describe single-cell aspiration dynamics. The spring constant $k$ represents the elastic response, and $\xi_\mathrm{f}$ represents the effective viscous resistance. (c) Aspiration length $L_\mathrm{p}$ over 10 seconds for three $\lambda_\mathrm{D}$ values. (CC BY-NC-ND 4.0: Dolgitzer et al., 2026, Fig. 1)
single-cell-aspiration.xml
In spheroid_aspiration_main.xml, we constructed spheroids consisting of 500 cells. Aspiration was applied dynamically to a one-pixel-thick region at the aspirated front. To obtain stable aspiration dynamics, peripheral cells were assigned reduced shape stiffness, a temporarily increased effective force until initial entry to the pipette, and maintained contact with the pipette walls. In addition, local strengthening of cell-cell adhesion inside the pipette (akin to catch-bond dynamics under stress) produced sustained creep (Figure 2, Video 2).
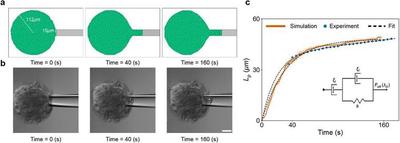
spheroid_aspiration_main.xml). (a) Simulated micropipette aspiration of a multicellular spheroid before aspiration (left), after $40\ \text{s}$ (middle), and after $160\ \text{s}$ (right). (b) Corresponding experimental images of a multicellular spheroid before aspiration and at the same time points. (c) Aspiration length as a function of time for the representative simulation and experiment. (CC BY-NC-ND 4.0: Dolgitzer et al., 2026, Fig. 3)
spheroid_aspiration_main.xml
Results
Both the experimental spheroid and the simulated spheroid exhibited an initially rapid increase in aspiration length followed by slower, sustained creep (see Figure 2). Increasing $\lambda_\mathrm{S}$ substantially altered the mechanics of isolated cells but had limited influence on the effective elastic modulus of spheroids. In contrast, changes in $J$ produced pronounced effects on spheroid effective elastic modulus. Nevertheless, both parameters increased the spheroid retardation time governing the transition from the initial elastic response to long-time viscous deformation.
These findings suggest that multicellular elasticity is governed primarily by intercellular mechanical coupling, whereas the dynamical response to applied stress depends jointly on cell-scale mechanics and cell-cell adhesion.
Reference
This model is the original used in the publication, up to technical updates:
D. Dolgitzer, E. Parajón, D. N. Robinson, P. A. Iglesias: Contributions of single-cell mechanics and cell-cell adhesion to multicellular spheroid mechanics. bioRxiv 2026.08.04.742605, 2026.
The model originates from a preprint and thus has not been formally peer-reviewed.
Model
spheroid_aspiration_main.xml
XML Preview
<?xml version='1.0' encoding='UTF-8'?>
<MorpheusModel version="4">
<Description>
<Details>Model ID: https://identifiers.org/morpheus/M3799
File type: Main model
Software: Morpheus (open source). Download from: https://morpheus.gitlab.io
Full title: Contributions of Single-cell Mechanics and Cell-cell Adhesion to Multicellular Spheroid Mechanics
Authors: D. Dolgitzer, E. Parajón, D. N. Robinson, P. A. Iglesias
Submitter: D. Dolgitzer
Curator: D. Jahn
Date: 28.09.2026
Reference: This model is the original used in the publication, up to technical updates:
D. Dolgitzer, E. Parajón, D. N. Robinson, P. A. Iglesias: Contributions of single-cell mechanics and cell-cell adhesion to multicellular spheroid mechanics.
bioRxiv 2026.08.04.742605, 2026.
Comment: This model simulates micropipette aspiration of a spheroid made of 500 cells, used in ‘Contributions of single-cell mechanics and cell-cell adhesion to multicellular spheroid mechanics’ by Dolgitzer et al., 2026.</Details>
<Title>M3799 Spheroid Aspiration</Title>
</Description>
<Space>
<Lattice class="square">
<Neighborhood>
<Order>1</Order>
</Neighborhood>
<Size symbol="size" value="380, 250, 0"/>
</Lattice>
<SpaceSymbol symbol="space"/>
</Space>
<Time>
<StartTime value="0"/>
<StopTime value="28000"/>
<TimeSymbol symbol="time"/>
</Time>
<CellTypes>
<CellType class="medium" name="medium">
<Property symbol="medium_distance" value="0.0"/>
<Property symbol="medium_contact" value="0.0"/>
</CellType>
<CellType class="biological" name="cell">
<VolumeConstraint target="80" strength="1" tags="cell"/>
<SurfaceConstraint target="1" strength="1*periphery" tags="cell" mode="aspherity"/>
<DirectedMotion direction="1, 0, 0" name="aspiration" strength="(time >= 10)*if((protrusion <= pipette_edge), asp_force, vacuum*if(L < 2, 1.5,asp_force))"/>
<Property symbol="medium_distance" value="0.0"/>
<Property symbol="medium_contact" value="0.0"/>
<Property symbol="buffer" value="10000.0"/>
<NeighborhoodReporter name="medium_contact">
<Input scaling="cell" value="cell.type == celltype.medium.id"/>
<Output symbol-ref="medium_contact" mapping="maximum"/>
</NeighborhoodReporter>
<System solver="Dormand-Prince [adaptive, O(5)]">
<Rule symbol-ref="medium_distance">
<Expression>if(medium_contact==1, sqrt(cell.volume/pi), buffer + sqrt(cell.volume/pi))</Expression>
</Rule>
<Rule symbol-ref="periphery">
<Expression>if(medium_distance <= 1.5*sqrt(cell.volume/pi),0.5,1)</Expression>
</Rule>
<Rule symbol-ref="stress_timer">
<Expression>if(stress_region_local == 1, stress_timer + 0.1, 0)</Expression>
</Rule>
</System>
<Property symbol="periphery" value="0.0"/>
<Property symbol="aspiration_timer" value="0.0"/>
<Property symbol="stress_timer" value="0.0"/>
<Mapper name="stress_region_local">
<Input value="stress_region"/>
<Output symbol-ref="stress_region_local" mapping="maximum"/>
</Mapper>
<Property symbol="stress_region_local" value="0.0"/>
<Function symbol="L">
<Expression>(protrusion - pipette_edge)*(protrusion > pipette_edge+1)</Expression>
</Function>
<Mapper name="protrusion">
<Input value="space.x"/>
<Output symbol-ref="protrusion" mapping="maximum"/>
</Mapper>
<Variable symbol="protrusion" value="0.0"/>
<ConnectivityConstraint/>
</CellType>
<CellType class="biological" name="pipette">
<FreezeMotion>
<Condition>1</Condition>
</FreezeMotion>
</CellType>
</CellTypes>
<CPM>
<Interaction>
<Contact type1="cell" type2="cell" value="-50*exp(min( (cell1.stress_timer + cell2.stress_timer)/(2*800),ln(1.5)))"/>
<Contact type1="cell" type2="pipette" value="-15*(space.y<pipette_top)*(space.y>pipette_bot)"/>
</Interaction>
<ShapeSurface scaling="norm">
<Neighborhood>
<Order>optimal</Order>
</Neighborhood>
</ShapeSurface>
<MonteCarloSampler stepper="edgelist">
<MCSDuration value="0.1"/>
<MetropolisKinetics temperature="0.2"/>
<Neighborhood>
<Order>optimal</Order>
</Neighborhood>
</MonteCarloSampler>
</CPM>
<CellPopulations>
<Population type="cell" name="spheroid" size="0">
<InitCircle number-of-cells="500" mode="regular">
<Dimensions radius="112" center="123.0, 125.0, 0.0"/>
</InitCircle>
</Population>
<Population type="pipette" name="pipette" size="0">
<InitCellObjects mode="distance">
<Arrangement displacements="0, 30.5, 0" repetitions="1, 2, 1">
<Box origin="pipette_edge, pipette_bot-0.5, 0.0" size="140.0, 0.5, 0.0"/>
</Arrangement>
</InitCellObjects>
</Population>
</CellPopulations>
<Analysis>
<Gnuplotter time-step="500">
<Terminal name="png"/>
<Plot>
<Cells opacity="0.5" value="periphery"/>
<Field symbol-ref="vacuum">
<ColorMap>
<Color value="0" color="white"/>
<Color value="1" color="gray70"/>
</ColorMap>
</Field>
</Plot>
</Gnuplotter>
<ModelGraph format="dot" reduced="false" include-tags="#untagged,cell"/>
<Logger time-step="10.0">
<Input>
<Symbol symbol-ref="L"/>
</Input>
<Output>
<TextOutput file-separation="cell"/>
</Output>
<Restriction>
<Celltype celltype="cell"/>
</Restriction>
</Logger>
</Analysis>
<Global>
<Constant symbol="asp_force" value="0.6"/>
<Field symbol="vacuum" value="0.0"/>
<Constant symbol="pipette_edge" value="240"/>
<Constant symbol="pipette_top" value="140"/>
<Constant symbol="pipette_bot" value="110"/>
<Function symbol="pipette_mid">
<Expression>(pipette_top + pipette_bot)/2</Expression>
</Function>
<Constant symbol="vacuum_thickness" value="1"/>
<Variable symbol="protrusion_top" value="0.0"/>
<Variable symbol="protrusion_mid" value="0.0"/>
<Variable symbol="protrusion_bot" value="0.0"/>
<Mapper name="protrusion_top">
<Input value="(cell.type==celltype.cell.id)*(space.x)*(space.y==pipette_top-1)"/>
<Output symbol-ref="protrusion_top" mapping="maximum"/>
</Mapper>
<Mapper name="protrusion_mid">
<Input value="(cell.type==celltype.cell.id)*(space.x)*(space.y==pipette_mid)"/>
<Output symbol-ref="protrusion_mid" mapping="maximum"/>
</Mapper>
<Mapper name="protrusion_bot">
<Input value="(cell.type==celltype.cell.id)*(space.x)*(space.y==pipette_bot+1)"/>
<Output symbol-ref="protrusion_bot" mapping="maximum"/>
</Mapper>
<System solver="Dormand-Prince [adaptive, O(5)]">
<Rule symbol-ref="vacuum">
<Expression>(space.y >= pipette_bot) * (space.y <= pipette_top) *
(space.x >= max(pipette_edge, front))</Expression>
</Rule>
<Function symbol="top_x">
<Expression>max(pipette_edge, protrusion_top - vacuum_thickness)</Expression>
</Function>
<Function symbol="mid_x">
<Expression>max(pipette_edge, protrusion_mid - vacuum_thickness)</Expression>
</Function>
<Function symbol="bot_x">
<Expression>max(pipette_edge, protrusion_bot - vacuum_thickness)</Expression>
</Function>
<Function symbol="front">
<Expression>if(space.y <= pipette_mid,
bot_x + (mid_x - bot_x) * (space.y - pipette_bot) / (pipette_mid - pipette_bot),
mid_x + (top_x - mid_x) * (space.y - pipette_mid) / (pipette_top - pipette_mid)
)</Expression>
</Function>
<Annotation>vacuum is applied dynamically to match the protrusion front at a thickness of 1 pixel.</Annotation>
</System>
<Field symbol="stress_region" value="if((space.x>=pipette_edge+2)*(space.y>=pipette_bot)*(space.y<=pipette_top),1,0)"/>
</Global>
</MorpheusModel>
Downloads
Files associated with this model: